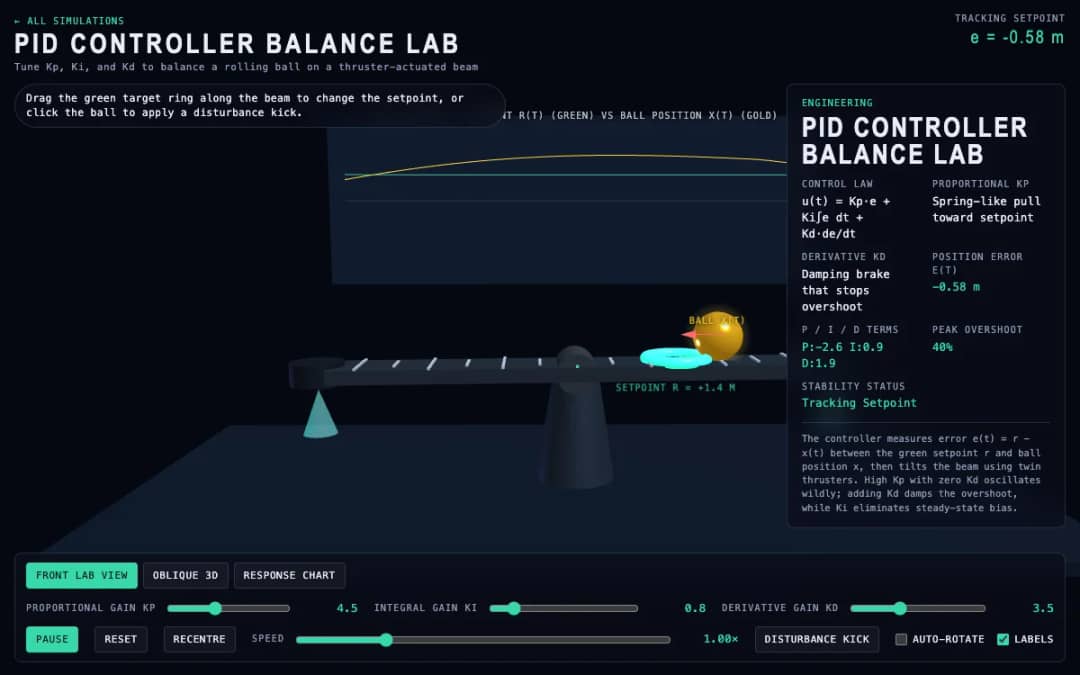
[Es] Balance a rolling metallic sphere on a thruster-actuated seesaw beam using a closed-loop PID controller. Drag the green target setpoint ring, kick the ball with impulse disturbances, and tune Proportional (Kp), Integral (Ki), and Derivative (Kd) gains while watching the real-time response chart.
—




 Inicio
 Todas las soluciones
 Precios
 Quiénes somos
 KiwiBee para organizaciones sin fines de lucro
 Eventos y seminarios web
 Para grandes organizaciones
 Para escuelas
 Para centros de aprendizaje
 Para líderes de equipo
 Para docentes
 IA y recursos
 Recursos
 Hojas de trabajo imprimibles
 Paquetes didácticos
 Simulaciones interactivas
 Herramientas para docentes
 Estudio de IA
 Ideas e investigación